Core concept
Robot Skin for Humanoid Robots: Materials, Sensing and Vendors
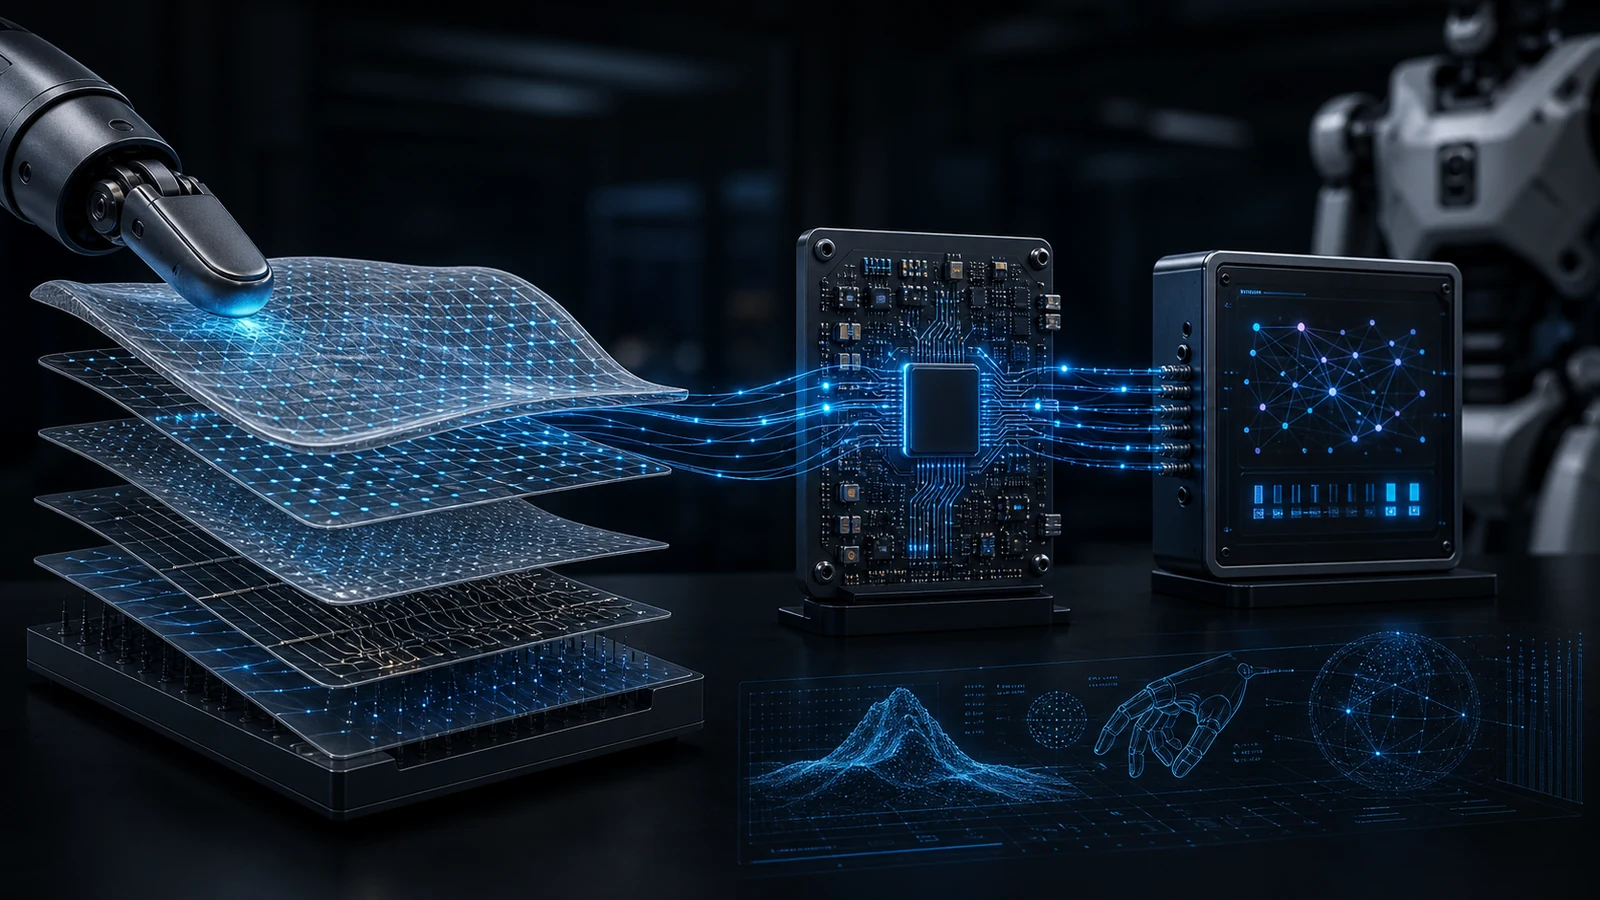
Robot skin is the engineered, sensor-bearing covering on a physical humanoid or robotic arm, not a game cosmetic. Robot skin combines compliant materials, embedded sensing, signal processing and a connection to robot control. Compare surface coverage, measurable contact signals, mounting requirements and vendor documentation before selecting a system.
Last updated:
Updated by RoboSkin.ai Editorial Team
November 4, 2026: reviewed system definitions and added an installation evidence record. Source-specific research and original anchors retained; no new hardware test.
Short answer
What you need to know
- 1
Robot skin is a sensing surface installed on a robot. Depending on its architecture and calibration, it may provide contact, pressure, shear or slip-related information; no single modality list applies to every skin.
- 2
A useful robot skin system is not only a soft cover. It includes sensor materials, signal conditioning, data handling, robot middleware, and control logic that can use touch information.
- 3
The term overlaps with e-skin and tactile sensors, but robot skin is usually discussed in the context of robots that need distributed contact awareness.
Topic 01
Specify the installed skin, not just the sensing material
A useful supplier or lab handoff identifies the complete installed assembly. The same sensing material can behave differently after a change in its thickness, support, electrode or magnet placement, cover, cable route or inference model. Record the configuration that produced the evidence before deciding which results apply to your robot.
The original DIGIT paper describes a modular optical fingertip with a replaceable elastomer; the ReSkin work separates the magnetic interface from the electronics. These designs make replacement practical, but they do not make every replacement equivalent. The hydrogel hand study adds a different case: selected electrical configurations depend on a particular continuous surface and electrode arrangement. Those are distinct service and calibration problems.
| Record | Concrete information | Decision it supports |
|---|---|---|
| Assembly identity | Sensor revision, surface material, cover, mounting support and connector route | Whether a specification belongs to the installed device |
| Coverage and access | Contact zones, joints, seams, exclusions and reachable maintenance points | Which task contacts are observed and which remain blind |
| Measurement chain | Raw output, calibration/model revision, units and timestamps | Whether the controller receives a measurement, an estimate or only an image |
| Replacement boundary | What changes when the surface or module is replaced | Which baseline, reference and task checks must be repeated |
| Evidence status | Dated manufacturer specification, author experiment or local measurement | What is documented versus established on the target robot |
A replacement example without invented performance data
Suppose an optical pad is replaced and the unloaded image changes. Preserve the old and new surface identifiers, mounting state, camera settings and reference observations. First determine whether acquisition changed; then evaluate the calibrated estimate; only then compare the task. A working camera stream does not establish that a prior force model still applies. This is an illustrative diagnostic sequence, not a test we performed.
Cost follows this assembly boundary too. A sensor-only fabrication estimate omits acquisition electronics, fixtures, replacement stock and engineering time. Use dated quotes and your actual integration plan; the category name does not establish a comparable purchase price.
Topic 02
What robot skin measures
Robot skin can measure contact location, pressure distribution, shear, slip, temperature, damage events, or other surface interactions depending on the sensor architecture. The exact signal matters more than the label.
A fingertip skin for dexterous manipulation may need high-resolution force and slip information. A body surface for human-robot interaction may need broader coverage, lower resolution, and reliable contact-event detection.
- Contact events across fingertips, palms, grippers, arms, and curved covers
- Pressure or force patterns rather than a single yes-or-no touch signal
- Slip, shear, vibration, or texture signals when manipulation requires them
- Timestamped data that can be logged, replayed, and used by controllers
Topic 03
How robot skin fits the tactile AI stack
Robot skin becomes more useful when it is part of a tactile AI stack. The surface gathers signals, electronics condition those signals, software organizes them into robot-ready data, and control systems use the result for grasping, safety, or evaluation.
Material properties alone do not establish an operational system. Calibration, mounting, latency, durability and software interfaces determine which robot behaviors the skin can support.
Topic 04
Robot skin sensor taxonomy
A practical robot skin taxonomy should classify a surface by modality, coverage, geometry, durability, and data interface before comparing sensitivity claims. Those dimensions tell readers whether a sensor belongs on a fingertip, palm, gripper pad, arm cover, soft robot, or full humanoid surface.
The taxonomy also separates materials research from robot integration. A flexible e-skin sample, optical tactile pad, pressure matrix, or multimodal skin can all be relevant, but the useful category depends on how the signal survives mounting and reaches robot software.
- Modality: pressure, shear, slip, strain, vibration, temperature, proximity, or multimodal contact
- Coverage: fingertip, full hand, gripper pad, arm surface, soft body, or large-area tactile skin
- Geometry and durability: flat sample, curved surface, jointed segment, replaceable layer, or wear-prone cover
- Data interface: analog readout, calibrated map, timestamped stream, middleware topic, or controller feature
Topic 05
Types of robot skin: compare the signal, not only the material
A soft contact surface can use very different sensing mechanisms. The examples below show how a physical interaction becomes an observation; they are not a ranking of accuracy, durability or readiness. A compact fingertip and a distributed hand surface also solve different coverage problems.
DIGIT is a vision-based tactile sensor, ReSkin separates a replaceable magnetic interface from the sensing electronics, and Cambridge’s single-material skin uses electrical impedance measurements and learned interpretation. The linked original sources establish these mechanisms; selecting and validating an installation remains a separate engineering task.
| Sensing route | What is observed | Example and coverage context | What to check for your task |
|---|---|---|---|
| Optical tactile sensing | A camera observes changes in the deformable contact surface. | Original DIGIT: a compact sensor designed for in-hand manipulation. | Mounting space, illumination and gel condition; verify the calibration used to infer depth or force. |
| Magnetic tactile skin | Magnetic-field changes caused by deformation of a magnetic interface. | ReSkin: replaceable soft interfaces with separate electronics. | Skin placement, magnetic environment and response changes after replacement; validate the response model. |
| Conductive continuous skin | Electrical measurements across a soft conductive material. | Cambridge/UCL single-layer skin: a hand-shaped research prototype using electrical impedance tomography. | Electrode layout and training conditions; separate contact interpretation from a calibrated physical quantity. |
| Capacitive textile skin | Capacitance changes associated with the sensing structure. | The linked twisted-yarn preprint compares layer configurations in a small research prototype. | Pressure and proximity requirements, mounting and coverage; prototype results do not establish whole-body performance. |
Topic 06
How robot skin works: from contact to usable feedback
Start with the quantity the task needs: a contact event, location, calibrated force estimate or a prediction such as slip risk. These are different outputs. A raw image, resistance or magnetic reading does not become a force measurement simply because software displays a number.
Use the following sequence as a planning checklist. It is an editorial workflow, not a hardware test result or a safety certification procedure. Keep the evidence for each stage with the data so another researcher can see which parts were actually checked.
- Define the task and contact zones, then record the sensor version, mounting geometry and replaceable surface.
- Capture raw readings with timestamps and validity flags; identify missing samples and the coordinate frame.
- Record calibration inputs, reference measurements and the range of conditions actually checked.
- Align touch, robot state and action timestamps; measure observed delays rather than assuming the requested sample rate was achieved.
- Evaluate the task with a stated baseline, independent trials and failure counts; keep inferred contact state separate from the executed robot response.
Topic 07
Where robot skin is used
Robot skin appears across humanoid robot hands, robotic grippers, e-skin research, flexible tactile sensors, prosthetics, and Physical AI. These areas overlap, but they raise different engineering questions.
RoboSkin.ai separates definitions, applications, technologies, comparisons, and research so readers can move directly to the level of detail they need.
Topic 08
Latest evidence: textile architecture changes the sensing tradeoff
The August 2026 twisted-yarn preprint provides a dated example of system trade-offs; it is not a claim to be the latest available research. Its comparison of one-, two-, and four-layer capacitive sensors shows why robot skin must be specified as a system. Increasing yarn-layer overlap improved the reported pressure sensitivity and tensile behavior, but proximity range decreased from 60 mm for one layer to 40 mm for four layers.
The result is not evidence for one universally superior geometry. It separates two task requirements: early approach detection before contact and stronger measurement after contact. The source is a small 4 × 4 research prototype, so whole-body scaling, abrasion, manufacturing yield, and field lifetime remain open questions.
Common questions
FAQ for this topic
Is robot skin the same as e-skin?
Not exactly. E-skin means electronic skin, often a flexible sensor layer. Robot skin usually means e-skin or tactile sensing used on a robot surface with robot-specific constraints.
Does robot skin replace vision?
No. Vision helps a robot see a scene before contact. Robot skin helps detect what happens at the contact surface after the robot touches an object or person.
What makes robot skin difficult?
The hard parts are flexible mounting, durability, wiring, calibration, signal quality, data rate, and connecting touch data to robot control or evaluation workflows.